Repository navigation

Replies: 3 comments 12 replies

|
Hello, KickCAT rely on the eeprom configuration on each slaves to determine which ressources (SyncManager, FMMU) to use. The crash you encountered seems to be due to a eeprom that do not have a sync manager section fully described. You can check this with the printInfo() after the bus initialization. For instance this is what I get with a working device (CANOpen): Be sure to have SM and FFMU entries for logical accesses (Input/Output, not mailbox). |

|
You are calling printInfo() function on a slave that does not come from the bus: this is why the data are outlier. Slave& slave_0 = bus.slaves().at(0);
printInfo(slave_0); |

|
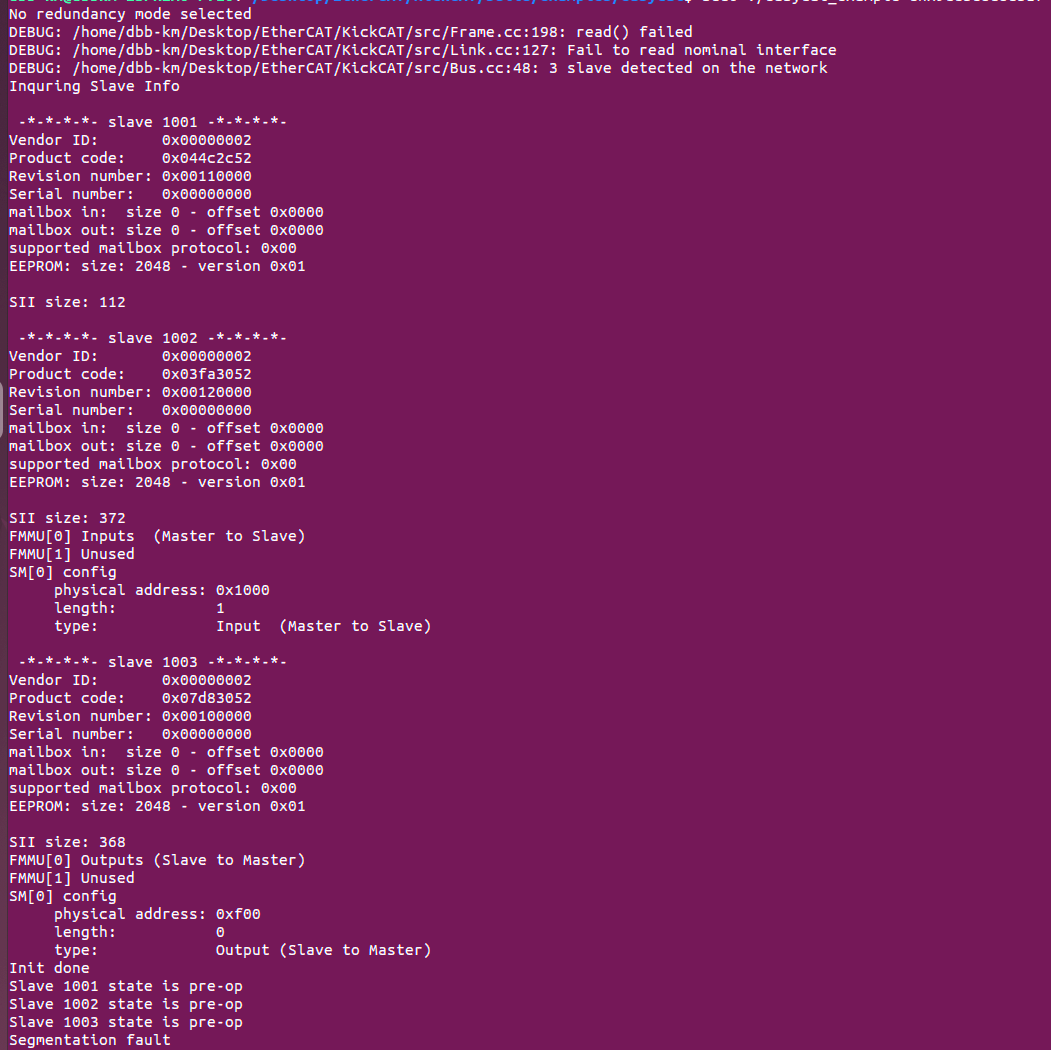
I called the print info, it is giving the proper information about slaves. Please look at the screenshots. But still I see segmentation fault after bus initialization. |
|
OK so the eeproms of your slaves are coherent yet strangely configured. However it should not lead to a crash on our side so it seems that there is a bug on an edge case here. |
|
Sure, I have saved the eeprom files as you suggested. please have a look and let me know what could we do next. Thanks, |
|
Hello Kapil, I managed to find the bug in KickCAT thanks to your eeprom dump. A patch is waiting for test and approval (#97) |
|
Hello Kapil, The patch was merged today so you should be able to start the bus now. However you still need to adapt the easycat_example to suit your slaves configuration (slave 0 and 3 have no inputs nor outputs and 1 has only one byte input). If you don't adapt the example, the code will crash on output access (177 and 181). |

|
No activity since 2023 closing |


Uh oh!
There was an error while loading. Please reload this page.
Hello,
I came across this library and I am testing it on my BeckHoff EtherCat devices. When I executed the easycat example, it discovers the 3 slaves on the bus but when it tries to call bus.createMapping(io_buffer), it gives an segmentation fault error. The error seems at line 562 in bus.cc file. Has anyone came across this issue? Any help appreciated!!
All reactions