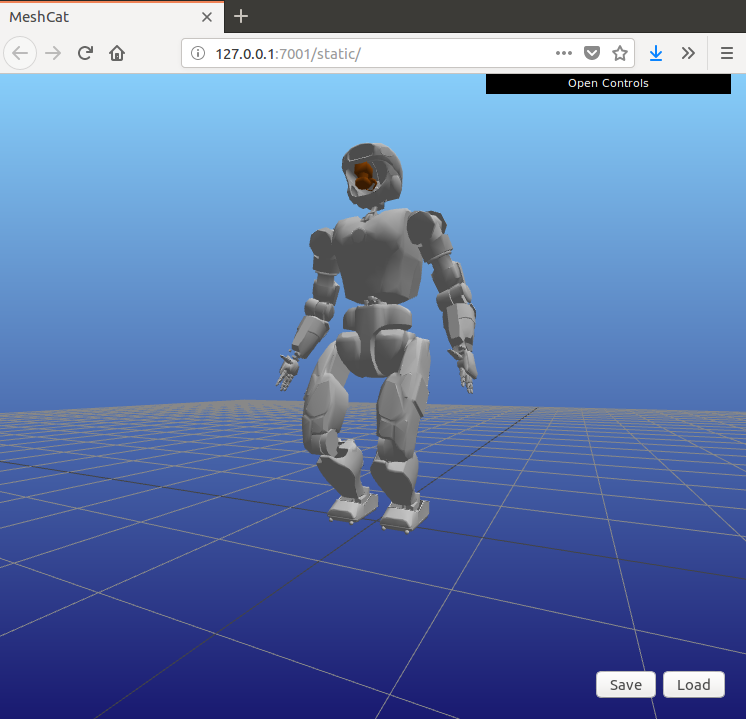
MeshCatMechanisms.jl adds support for visualizing mechanisms and robots from RigidBodyDynamics.jl with MeshCat.jl. All geometries are constructed using MechanismGeometries.jl.
Features:
- Parsing geometry directly from URDF files
- Animation of robot trajectories from RigidBodyDynamics.jl simulations
- Live rendering of simulation progress using the
OdeIntegrators.OdeResultsSinkinterface - Interactive manipulation of the mechanism configuration using InteractBase.jl
MeshCatMechanisms.jl provides similar functionality to RigidBodyTreeInspector.jl, but is built on top of the lighter-weight MeshCat viewer instead of DrakeVisualizer.jl.
Stable release:
Pkg.add("MeshCatMechanisms")Latest and greatest:
Pkg.add("MeshCatMechanisms")
Pkg.clone("https://github.com/rdeits/MechanismGeometries.jl")
Pkg.checkout("MeshCatMechanisms")
Pkg.checkout("MeshCat")